Clearpath Robotics RidgebackvsDobot Hexplorer
For university mobile manipulation research labs integrating collaborative arms (ur10, baxter) with perception and grasping experiments, Ridgeback is easier to deploy today — Hexplorer is the longer bet on capability.
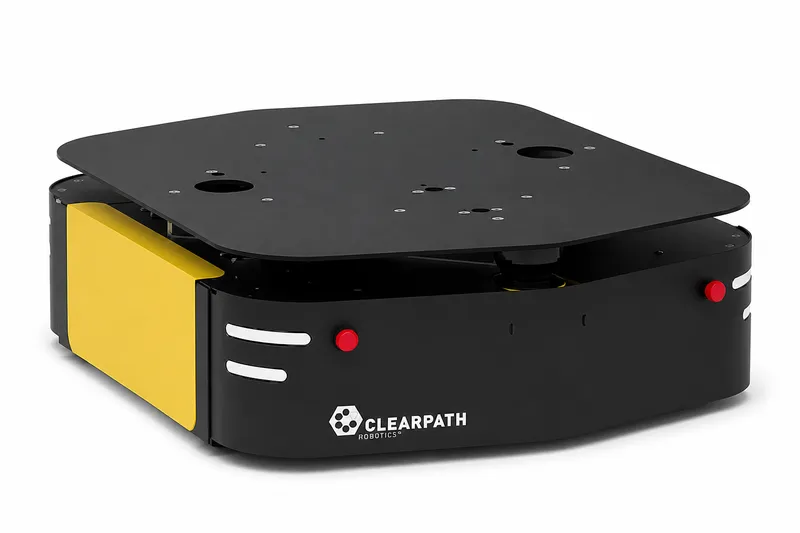
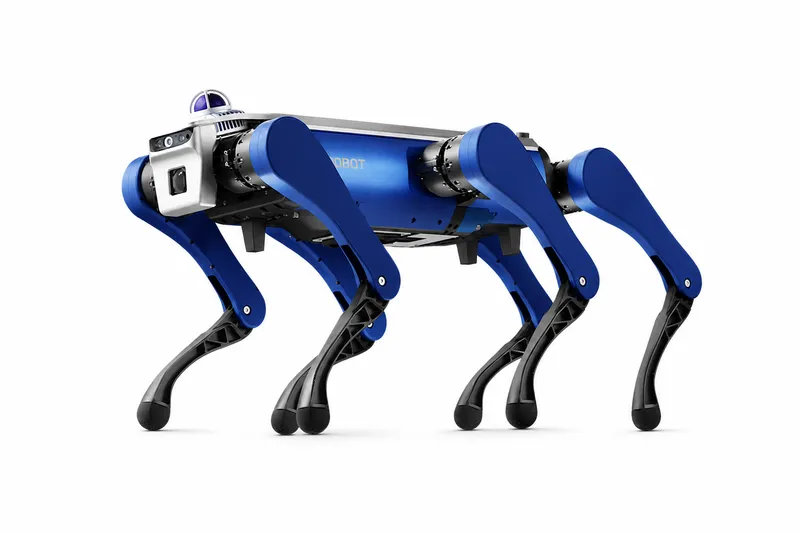
Ridgeback
1 wins
Hexplorer
0 wins
Category breakdown
Deploy & operate
Readiness, uptime, navigation & connectivity
- 80Deployment readiness62
- 60Maintenance confidence60
- Vision-led navigation (estimated)NavigationVision-led navigation (estimated)
- Wi-Fi / cloud fleet management (estimated)ConnectivityWi-Fi / cloud fleet management (estimated)
Cost & ROI
Price accessibility and ROI clarity
- 68Price accessibility81
- 65ROI clarity45
Capability
Payload, speed, runtime & labor replacement
- 55Labor replacement35
- 100 kgPayload10 kg (rated), 15 kg (max)
- 1.1 m/sSpeed1.8 m/s max walking speed
- up to 8 hoursBattery504 Wh battery; 2.5 h runtime
Fit & future
Environment fit, footprint & long-term upside
- 85Environment fit72
- 70Future potential78
- 960 × 793 × 296 mmFootprintStanding: 86.3 × 47 × 48 cm; Folded: 73.4 × 47 × 24.6 cm
Ridgeback · Best for
University mobile manipulation research labs integrating collaborative arms (UR10, Baxter) with perception and grasping experiments
Hexplorer · Best for
Utility tunnel and underground infrastructure inspection with 10 kg sensor payload
Final judgment
If immediate deployment is the priority, choose Ridgeback. If the goal is to be ready when Hexplorer's capabilities mature, track it.